Researchers develop interface for quadriplegics to control robots

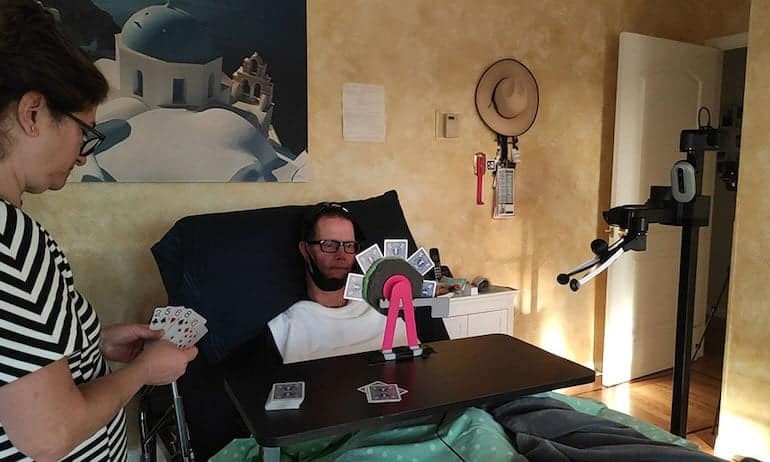
Carnegie Mellon University researchers lived with Henry and Jane Evans for a week to test their Head-Worn Assistive Teleoperation (HAT) device with Henry, who lost his ability to speak and move his limbs 20 years ago.

No one could blame Carnegie Mellon University students Akhil Padmanabha and Janavi Gupta if they were a bit anxious this past August as they traveled to the Bay Area home of Henry and Jane Evans.

The students were about to live with strangers for the next seven days. On top of that, Henry, a person with quadriplegia, would spend the week putting their Head-Worn Assistive Teleoperation (HAT) — an experimental interface to control a mobile robot — to the test.

The post Researchers develop interface for quadriplegics to control robots appeared first on The Robot Report.
More Related Posts

Edge to Exascale: A Trend to Watch in 2022

Edge computing is an approach in which the data is processed and...

Unity demos how synthetic data can help robots learn

Unity is showcasing how its AI and machine learning capabilities could benefit...

MassRobotics launches inaugural Robo Boston Festival

Robo Boston will take place in the innovative Boston Seaport neighborhood on...

Home

Highly Niched Headhunters Specialized in Physical AI/Robotics, High-Performance Computing, Unmanned/Autonomous Systems, Defense Technology and Energy.

Specializations

We recruit across complex engineering markets where understanding the technology is critical to finding the right talent.

How We Work

Overview of how PACE partners with teams: Our process, what clients get, and why PACE is different.

About Us

PACE’s story, values, and culture define how we operate and who we are.

News & Insights

Stay up to date on industry trends.

Contact

All the information needed for anyone interested in contacting us.