BADGR mobile robot learns to navigate on its own

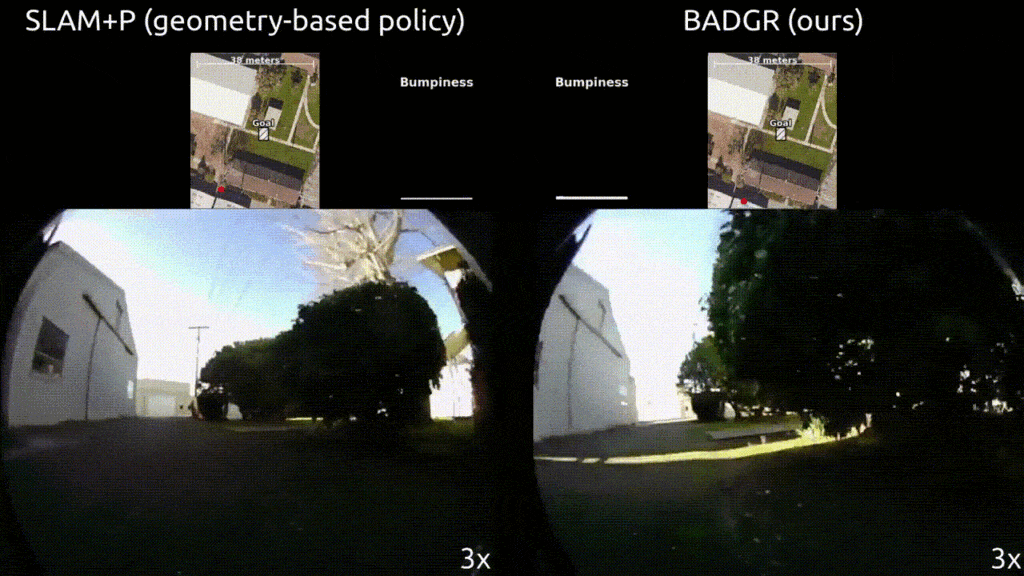
SLAM vs. BADGR

BADGR successfully reached its goal while avoiding collisions and bumpy terrain, unlike a geometry-based policy. Source: Greg Kahn, BAIR

A geometric approach to mobile robot navigation and obstacle avoidance may be sufficient for environments such as warehouses, but it might not be enough for dynamic settings outdoors. Researchers at the University of California, Berkeley, said they have developed BADGR, “an end-to-end, learning-based mobile robot navigation system that can be trained with self-supervised, off-policy data gathered in real-world environments, without any simulation or human supervision.”

The post BADGR mobile robot learns to navigate on its own appeared first on The Robot Report.

More Related Posts

CMU crawling robots map and repair natural gas pipelines

Researchers at Carnegie Mellon University’s Robotics Institute are creating robots that can...

Toyota Research Institute emphasizes safety of AI-assisted driving

The safety of autonomous vehicles has been called into question after incidents...

What do customers expect from mobile robots?

Mobile robots have become an essential part of the automation landscape in...

Home

Highly Niched Headhunters Specialized in Physical AI/Robotics, High-Performance Computing, Unmanned/Autonomous Systems, Defense Technology and Energy.

Specializations

We recruit across complex engineering markets where understanding the technology is critical to finding the right talent.

How We Work

Overview of how PACE partners with teams: Our process, what clients get, and why PACE is different.

About Us

PACE’s story, values, and culture define how we operate and who we are.

News & Insights

Stay up to date on industry trends.

Contact

All the information needed for anyone interested in contacting us.