Designing sit-to-stand motions for lower-limb exoskeletons

exoskeleton

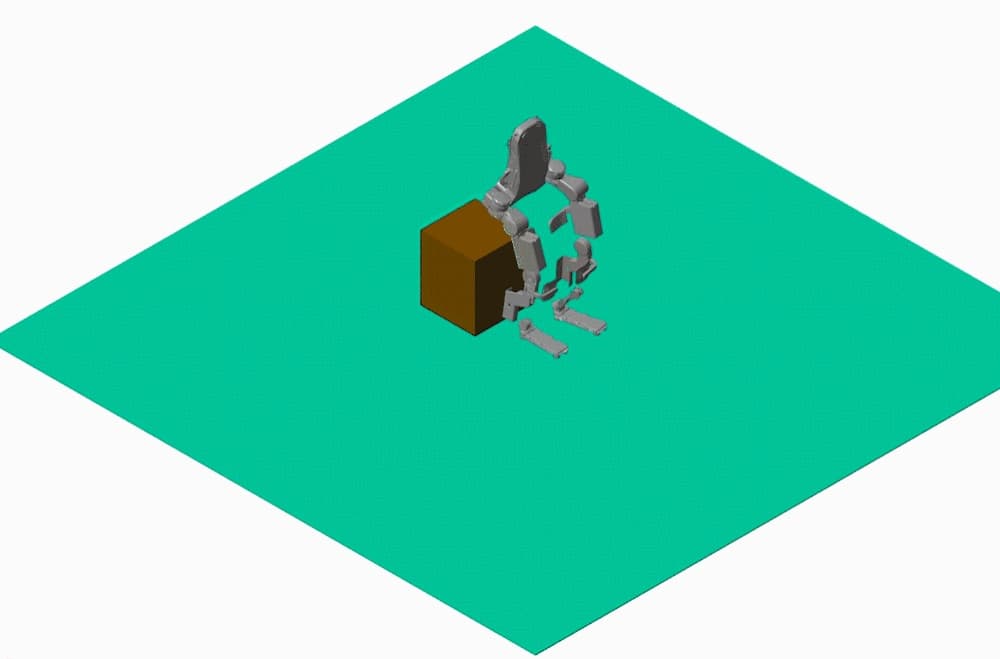
A virtual Atlante exoskeleton moving from sitting to standing position. | Credit: University of Michigan

Exoskeleton users can now go from sitting to standing safely and without assistance based on the work of University of Michigan researchers, who developed an approach to create and test solutions to such problems virtually.

“We now have a way to systematically design control objectives for highly constrained systems such that the objectives are not in conflict with the contact constraints,” said Eva Mungai, a PhD candidate in Mechanical Engineering.

The post Designing sit-to-stand motions for lower-limb exoskeletons appeared on The Robot Report.
More Related Posts

GM, JR Automation producing medical masks for COVID-19 pandemic

GM engineers working on testing and validation for the medical mask assembly...

Seven Minority-Serving Institutions Selected for Solar Research Funding through DOE Pilot Program

The U.S. Department of Energy (DOE), in collaboration with the Minority-Serving Institution...

Evolving humanoid robotic dexterity from toddler to adult

Something’s been forgotten in the race to build general-purpose humanoid robots. Roboticists...

Home

Highly Niched Headhunters Specialized in Physical AI/Robotics, High-Performance Computing, Unmanned/Autonomous Systems, Defense Technology and Energy.

Specializations

We recruit across complex engineering markets where understanding the technology is critical to finding the right talent.

How We Work

Overview of how PACE partners with teams: Our process, what clients get, and why PACE is different.

About Us

PACE’s story, values, and culture define how we operate and who we are.

News & Insights

Stay up to date on industry trends.

Contact

All the information needed for anyone interested in contacting us.