Designing a quadruped controlled & powered by pneumatics

quadruped soft robot

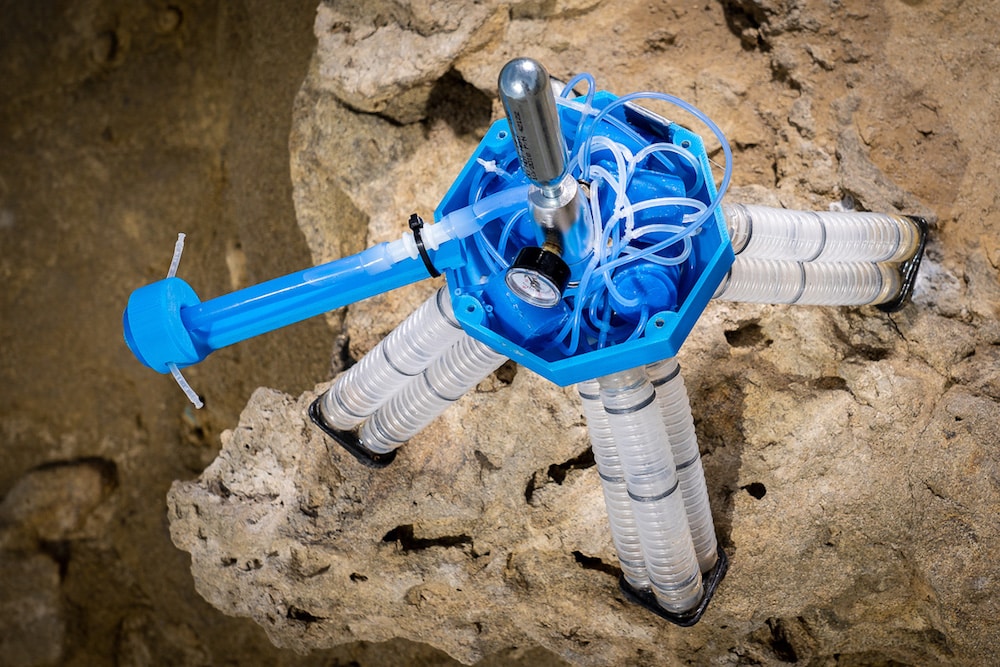
This quadruped relies on a series of valves that open and close in a specific sequence to walk. | Credit: UCSD

Engineers at the University of California San Diego have created a four-legged soft robot that doesn’t need any electronics to work. The quadruped only needs a constant source of pressurized air for all its functions, including its controls and locomotion systems.

The post Designing a quadruped controlled & powered by pneumatics appeared first on The Robot Report.
More Related Posts

AWS Takes the Short and Long View of Quantum Computing

It is perhaps not surprising that the big cloud providers – a...

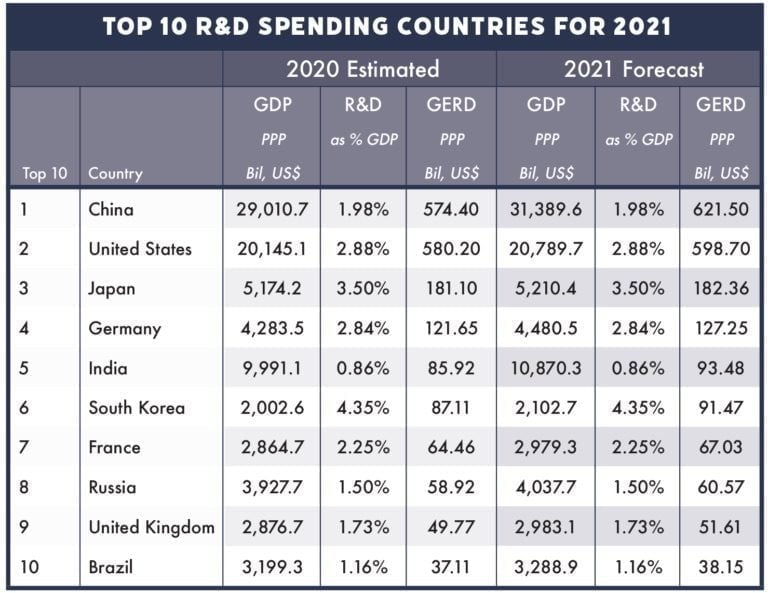
Global R&D Funding Forecast 2021

For 62 years, R&D World and its predecessors have published an annual...

Drone services critical to safer, more economical utility inspections, says PrecisionHawk

The difficulties of maintaining critical infrastructure are well known — millions of...

Home

Highly Niched Headhunters Specialized in Physical AI/Robotics, High-Performance Computing, Unmanned/Autonomous Systems, Defense Technology and Energy.

Specializations

We recruit across complex engineering markets where understanding the technology is critical to finding the right talent.

How We Work

Overview of how PACE partners with teams: Our process, what clients get, and why PACE is different.

About Us

PACE’s story, values, and culture define how we operate and who we are.

News & Insights

Stay up to date on industry trends.

Contact

All the information needed for anyone interested in contacting us.