Using tactile-based reinforcement learning for insertion tasks

tactile reinforcement learning

Collaborative robots (cobots) are designed to operate around humans in a factory environment and to execute tasks in a human-like fashion. Interestingly, assembly tasks that are simple for humans to perform such as gripping, grasping, turning and rotating items require highly sophisticated reinforcement learning (RL) protocols and tactile sensors for cobots to repeatedly successfully perform. Visual programming routines in the onboard software enable operators to program a robot via a “train by demonstration” graphical user interface. However, the technology behind these easily programmed and controlled robots is complex.

The post Using tactile-based reinforcement learning for insertion tasks appeared first on The Robot Report.
More Related Posts

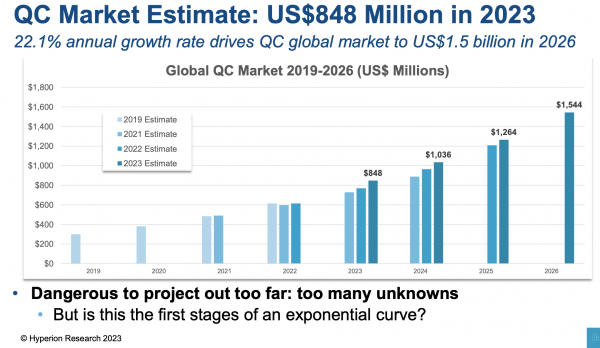
Quantum Market, Though Small, will Grow 22% and Hit $1.5B in 2026

Few markets as small as the quantum information sciences market generate as...

Transferring Data with Many Colors of Light Simultaneously

The data centers and high-performance computers that run artificial intelligence programs, such...

Human Brain Project Delivered Impressive Research Results

From November 21-24, the final Human Brain Project (HBP) review was held...

Home

Highly Niched Headhunters Specialized in Physical AI/Robotics, High-Performance Computing, Unmanned/Autonomous Systems, Defense Technology and Energy.

Specializations

We recruit across complex engineering markets where understanding the technology is critical to finding the right talent.

How We Work

Overview of how PACE partners with teams: Our process, what clients get, and why PACE is different.

About Us

PACE’s story, values, and culture define how we operate and who we are.

News & Insights

Stay up to date on industry trends.

Contact

All the information needed for anyone interested in contacting us.